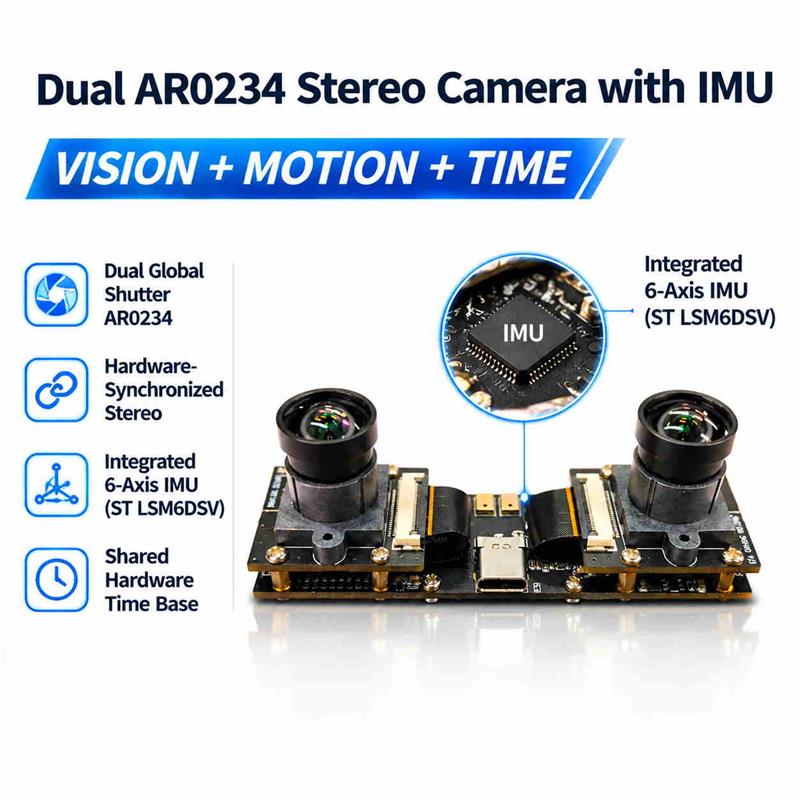
Capture synchronized stereo images and 6-axis motion data through a shared hardware time base. Designed for robot learning, egocentric recording and visual-inertial development
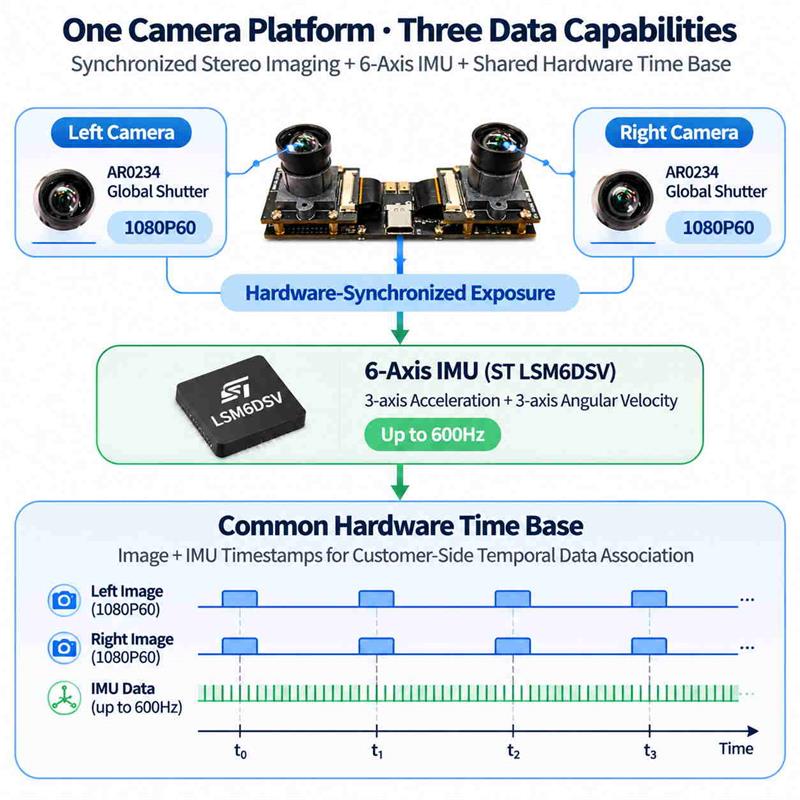
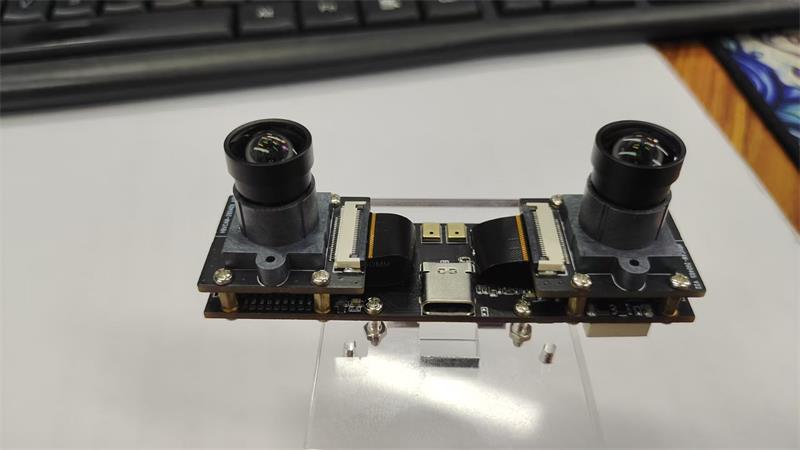
The Goobuy UC-AR0234-dual-imu is a synchronized stereo USB camera module combining two 2MP AR0234 global shutter sensors with an integrated ST LSM6DSV 6-axis IMU. It captures simultaneous stereo images and motion measurements with hardware timestamps on a shared time base, providing a compact vision-and-motion data acquisition platform for robotics, humanoid robot development, human-demonstration capture, teleoperation and visual-inertial research.
UC-AR0234-dual-imu | Dual Global Shutter · Hardware-Synchronized Stereo · 6-Axis IMU · Shared Hardware Time Base
Three Core Capabilities
Synchronized Stereo Vision: Two AR0234 global shutter cameras with hardware-synchronized left/right exposure.
Integrated Motion Sensing: 6-axis IMU providing 3-axis acceleration and 3-axis angular velocity, with sampling rates up to 600Hz.
Shared Hardware Time Base: Hardware timestamps associated with image frames and IMU data for customer-side temporal data association.
Designed for robotics engineering teams and OEM developers building their own visual and motion-data acquisition systems.
Robotics systems increasingly require visual observations and motion measurements to be collected together.
A stereo camera provides two synchronized visual perspectives of the environment. An IMU provides acceleration and angular velocity measurements as the device moves. A shared hardware time base provides timing information that allows customer software to associate image frames with corresponding inertial samples.
The Goobuy UC-AR0234-dual-imu combines these three capabilities in one camera module.
Stereo Image Acquisition
Two color AR0234 global shutter sensors capture synchronized left and right image streams for binocular vision and stereo-processing workflows.
Motion Data Acquisition
The integrated ST LSM6DSV IMU sensor records three-axis acceleration and three-axis angular velocity, with sampling rates up to 600Hz.
Common Hardware Time Reference
Image and IMU data carry hardware timestamps based on a common time base. The supplied Linux SDK is used to access and decode the timestamp information for customer-side data association.
Together, these capabilities provide a practical hardware foundation for engineering teams developing robotics perception, human-demonstration datasets, motion analysis and visual-inertial processing systems.
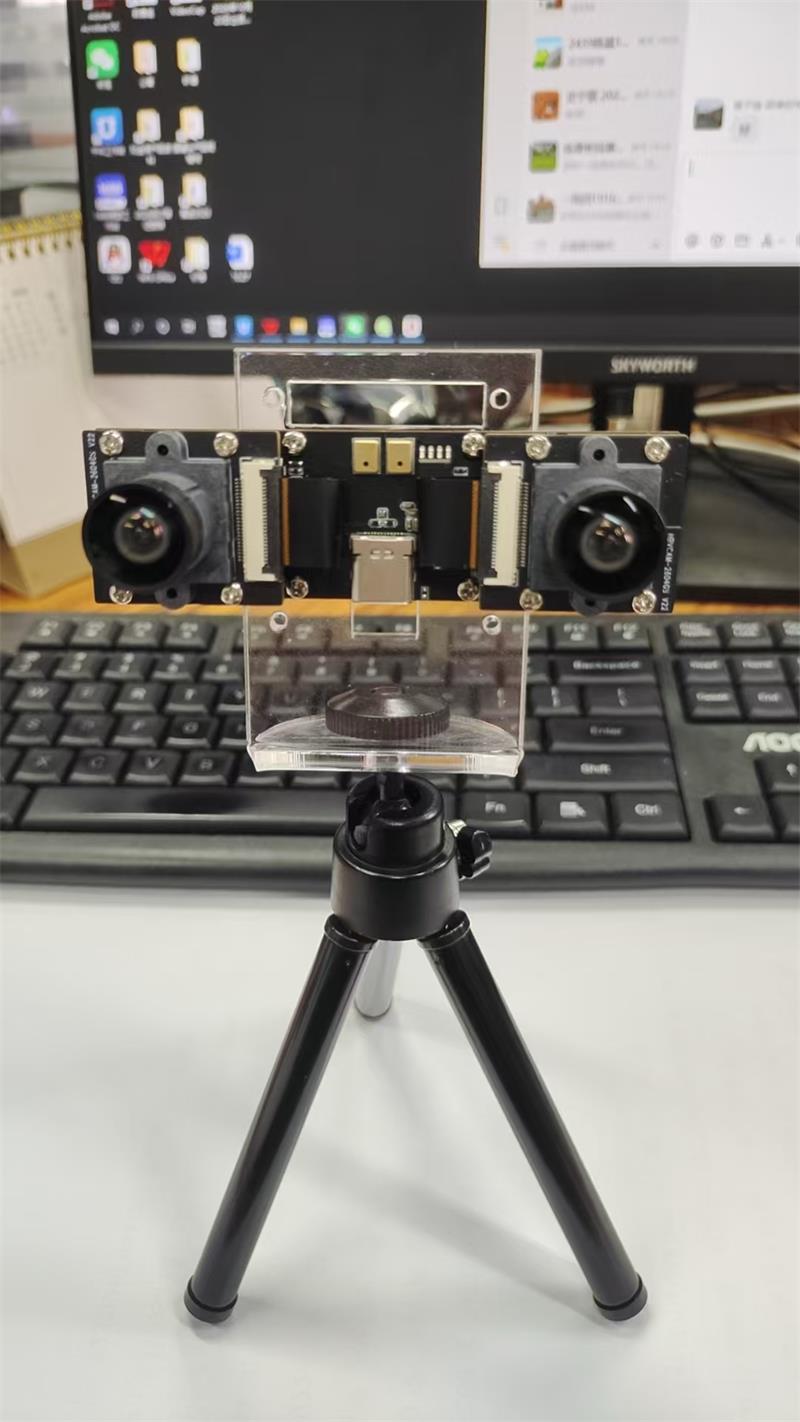
Robotics developers need real-world data to understand how humans interact with objects, tools and physical environments.
For manipulation and robot-learning workflows, video alone may not provide sufficient motion context. Synchronized stereo images and inertial measurements offer complementary visual and motion information.
The UC-AR0234-dual-imu can be integrated into customer-developed data collection equipment for:
Human manipulation demonstrations
Object handling and tool-use recording
First-person visual data collection
Robot-learning dataset acquisition
Human activity and motion analysis
Stereo visual observation during task execution
The dual-camera system captures synchronized color images, while the integrated IMU records device motion.
The shared hardware time base allows the customer's recording and processing software to associate visual and inertial measurements within the same data timeline.
This makes the module relevant to robotics startups, robot-learning companies and engineering teams developing their own human-demonstration capture hardware.
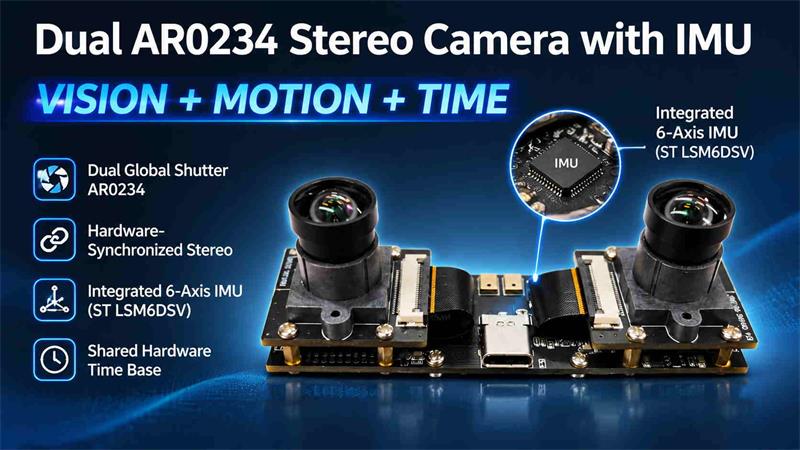
For first-person data collection, camera orientation and device movement are important parts of the recorded visual context.
The Goobuy stereo-IMU module can be evaluated for integration into:
Head-Mounted Vision Rigs
Stereo visual capture and motion sensing for head-mounted data collection devices used in robotics research and human activity recording.
Chest-Mounted Recording Equipment
Binocular image acquisition and device-motion data for wearable demonstration capture systems.
Portable Data Collection Devices
Compact camera hardware for mobile or portable visual-and-motion recording equipment.
Custom Robotics Research Equipment
Stereo-IMU imaging components for experimental perception and motion-data acquisition platforms.
The camera is an integration component, not a finished wearable recorder. Enclosure, mounting, battery, storage, recording software and application-level processing are provided by the customer's system.
Visual-inertial systems use camera observations and inertial measurements as complementary inputs for motion estimation and spatial perception.
The UC-AR0234-dual-imu provides:
Hardware-synchronized stereo image acquisition
Dual AR0234 color global shutter sensors
Integrated six-axis inertial sensing
Image and IMU hardware timestamps on a common time base
Linux SDK availability for data access
Potential development applications include:
Visual-inertial odometry (VIO) research
SLAM development
Stereo motion analysis
Egocentric tracking development
Robot localization research
Mobile robotics perception
Teleoperation and remote manipulation research
The camera supplies visual and inertial data, not finished VIO, SLAM, localization or mapping results. These functions require customer-developed or separately selected software and algorithms.
Both AR0234 sensors use global shutter technology.
Global shutter exposure captures the image frame simultaneously rather than exposing different image rows at different times as in rolling shutter imaging.
Combined with hardware-synchronized left/right exposure, this is useful for applications involving:
Moving robotic arms
Human manipulation demonstrations
Mobile robot movement
Conveyor-based inspection
Moving objects and equipment
Teleoperation operator-view systems
Hardware-synchronized exposure provides corresponding left/right image capture. The common time base additionally provides timing information for associating image and IMU data.
Important: A shared time base does not mean every IMU sample occurs exactly at a camera exposure instant. The SDK and customer-side processing pipeline are required to interpret and associate the timestamps.
The UC-AR0234-dual-imu uses a USB 3.1 interface and is designed for integration with compatible host computers and embedded systems.
Typical integration environments include:
Linux-based embedded computers
Robotics development platforms
Industrial PCs
AI edge computing devices
Custom wearable recording systems
OEM vision and sensing equipment
A Linux SDK is available for accessing the image and IMU timestamp workflow.
Standard UVC video viewing alone does not provide the complete image/IMU data workflow. The supplied SDK is required to decode timestamp information and associate image frames with IMU samples.
Customers should evaluate the actual USB host, SDK configuration, image output mode, CPU workload and continuous data acquisition performance before final system integration.
The 60fps stereo imaging mode uses MJPEG compression. It is not uncompressed dual-eye 60fps output.
Goobuy supplies the stereo-IMU camera hardware platform. Factory calibration is not included.
The following calibration procedures are the customer's responsibility and must be performed locally after the camera is installed in the final mechanical configuration:
Stereo camera calibration
Left/right camera intrinsic and extrinsic calibration
Camera-to-IMU spatial calibration
Application-specific sensor alignment and validation
Calibration should be performed using the customer's final mounting structure, camera position, operating environment and intended application.
Goobuy does not provide factory-calibrated stereo parameters, camera-to-IMU calibration files or calibration services as standard product deliverables.
The camera provides hardware-synchronized stereo exposure and image/IMU timestamps on a common time base. These hardware capabilities should not be interpreted as a guarantee of a particular synchronization error, calibrated sensor accuracy or application-level positioning performance.
Customers requiring specific synchronization tolerances, calibration evidence or additional triggering functions should confirm feasibility separately before ordering.
The UC-AR0234-dual-imu is a camera and inertial sensing hardware module, not a complete robotics perception or data collection system.
Standard hardware deliverables do not include:
Factory stereo calibration
Factory camera-to-IMU calibration
Calibration files or calibration services
Complete wearable recording equipment
Onboard video storage
Onboard AI processing
Human hand or body-pose tracking
Finished depth maps or point clouds
VIO / SLAM algorithms or localization results
Robot control or motion planning software
Customer-specific dataset generation or annotation
Native MIPI interface development
Customers provide their own host computer, recording software, algorithms, mechanical installation and local calibration process.
| Item | Specification |
|---|---|
| Model | UC-AR0234-dual-imu |
| Camera Type | Stereo USB Camera with Integrated IMU |
| Image Sensors | Dual AR0234 Color CMOS |
| Sensor Format | 1/2.6-inch |
| Pixel Size | 3.0μm |
| Shutter | Global Shutter |
| Stereo Output | Side-by-side left/right images |
| Full HD Stereo | Simultaneous 1920×1080 at 60fps per eye, as specified |
| MJPEG Mode | High-frame-rate compressed stereo output |
| YUY2 Mode | 3840×1200 at 10fps |
| Stereo Synchronization | Default hardware-synchronized exposure |
| IMU | STMicroelectronics LSM6DSV |
| Motion Data | 3-axis acceleration + 3-axis angular velocity |
| IMU Sampling | Up to 600Hz |
| Timestamping | Image and IMU hardware timestamps on a common time base |
| Interface | USB 3.1 |
| Power | USB bus power, DC 5V ±5% |
| Lens | 3.25mm, F2.6 |
| Nominal FOV | 100° diagonal |
| Focus | Fixed focus; assembly-adjustable working distance |
| Dimensions | 85 × 25 × 31.6mm ±0.5mm |
| Operating Temperature | -10°C to +60°C |
| Stable Imaging Range | 0°C to +50°C |
| Software | Linux SDK available |
| Factory Calibration | Not included |
| Customer Calibration | Required locally after final installation |
Video Output Note: The 60fps stereo mode uses MJPEG compression. Exact output dimensions, stream layout and SDK configuration should be confirmed against the selected firmware and sample configuration before ordering. YUY2 is available at a lower frame rate.
For an efficient technical evaluation, robotics engineering teams should confirm:
1. Stereo Image Requirements
Required per-eye resolution, frame rate, image format and stereo output layout.
2. IMU Requirements
Required acceleration and angular velocity ranges, sampling rate and raw data access.
3. Timestamp Requirements
How the host software accesses image and IMU timestamps, and what timing accuracy the application requires.
4. Host Integration
Linux distribution, USB host controller, available bandwidth and processing capability.
5. Mechanical Configuration
Camera mounting position, baseline compatibility, cable routing, lens FOV and working distance.
6. Calibration Responsibility
The customer's engineering team must perform stereo and camera-to-IMU calibration locally after final mechanical installation.
7. Application Stage
Prototype development, engineering validation or pilot production.
Confirming these requirements before sample purchase helps avoid unnecessary customization and engineering discussions.
It combines three capabilities in one hardware module: dual hardware-synchronized AR0234 global shutter imaging, an integrated six-axis IMU, and image/IMU hardware timestamps on a common time base.
A standard stereo camera without an IMU does not provide the same integrated visual-and-motion data acquisition configuration.
Yes. The specified configuration supports simultaneous 1920×1080 imaging at 60fps per eye using MJPEG compression.
It is not uncompressed dual-eye 60fps output. Confirm the exact output dimensions, layout and firmware configuration during sample evaluation.
The camera uses the STMicroelectronics LSM6DSV six-axis IMU, providing three-axis acceleration and three-axis angular velocity measurements.
The specified maximum IMU sampling rate is up to 600Hz.
The left and right camera sensors use hardware-synchronized exposure. Image and IMU data also carry hardware timestamps based on a common time base.
The supplied SDK is required to access and decode the timestamp information for customer-side data association.
A common time base does not mean that every IMU sample occurs exactly at an image exposure instant.
No. Factory stereo calibration and factory camera-to-IMU calibration are not included.
Customers must perform both stereo calibration and camera-to-IMU calibration locally after installing the camera in their final mechanical configuration.
Goobuy supplies the camera and IMU hardware, not factory calibration files or calibration services.
It can be evaluated as a stereo-image and inertial-data input device for customer-developed VIO, SLAM and visual-inertial processing systems.
The camera does not include finished VIO, SLAM or localization algorithms. Customers are responsible for software integration and calibration.
Yes. The synchronized stereo images and IMU motion data can serve as hardware inputs for human-demonstration recording, egocentric capture and robot-learning data collection systems.
The customer's equipment must provide the required mounting, power, storage and recording software.
Yes, it can be evaluated as a camera module for customer-designed head-mounted, chest-mounted or portable stereo-IMU recording equipment.
The wearable enclosure, battery, mounting structure, storage and recording application are not included in the standard camera module.
No. It supplies synchronized stereo images and IMU data.
Depth estimation, point-cloud generation, motion tracking and spatial reconstruction require separate customer-side processing software.
Yes. A Linux SDK is available for the image and IMU timestamp workflow.
The SDK is required to decode timestamp information and associate image frames with IMU samples. Specific Linux distribution compatibility and integration requirements should be confirmed during sample evaluation.
No. The current UC-AR0234-dual-imu platform is supplied through USB. Native MIPI development is not offered.
Goobuy can review practical configuration requirements around the existing hardware platform, including lens, focus distance, cable, connector routing, mounting, housing and packaging.
Major PCB redesign, new interfaces, special firmware and application software development are outside the standard configuration scope and require separate feasibility review.
Goobuy specializes in compact USB cameras, global shutter cameras, synchronized imaging hardware, rugged AHD cameras and specialized camera optics for OEM and industrial applications.
We work with equipment manufacturers, robotics developers and system integrators that need practical camera hardware for their existing host systems and products.
Our approach is to start with existing camera platforms and support reasonable configuration around lenses, cables, connectors, housings and mounting requirements.
For specialized stereo-IMU applications, Goobuy provides the existing dual-camera and motion-sensing hardware platform for paid sample evaluation and customer-side integration.
We focus on repeatable hardware configurations and practical OEM supply rather than undertaking complete robotics software, calibration or algorithm development projects.
Goobuy Dual AR0234 Stereo USB Camera (okgoobuy.com)
 office@okgoobuy.com
Follow Me
Address:A615, 6F, Huachuangda Building, No107 Xinghua 1st Road, 43 District, Xinan street, Baoan, shenzhen, China 518101